
End effectors
Grippers and end effectors
Most manipulation tasks do not need five fingers. They need repeatable force on a part whose geometry varies — which is a different, cheaper, more reliable problem.
The honest framing
When five fingers are overkill
A dexterous hand earns its cost when the task requires in-hand reorientation, human-tool use, or a policy trained on human demonstrations that must transfer to a human-shaped end effector. That is a real set of problems — but it is a smaller set than most procurement lists assume.
If the task is pick, place, machine-tend, or bin-pick, a parallel or multi-finger gripper will be faster to integrate, cheaper to run, more repeatable over millions of cycles, and easier to service. The interesting middle ground is a multi-finger gripper: 6 to 18 degrees of freedom, industrial buses and cycle life, but enough adaptability to handle parts that are not identical. That is the slot TESOLLO occupies, and almost nobody else does.
Choose parallel
Identical parts, fixed geometry
Highest cycle life, lowest cost, simplest integration. If every part is the same shape, stop here.
Choose multi-finger
Variable geometry, known task
Adapts to part variation without needing a full anthropomorphic hand or human-demonstration training data.
Choose a hand
In-hand manipulation or human transfer
Reorientation, tool use, or a policy trained on human hands.
In the catalog
Available now
In the Knoxlabs catalog today.
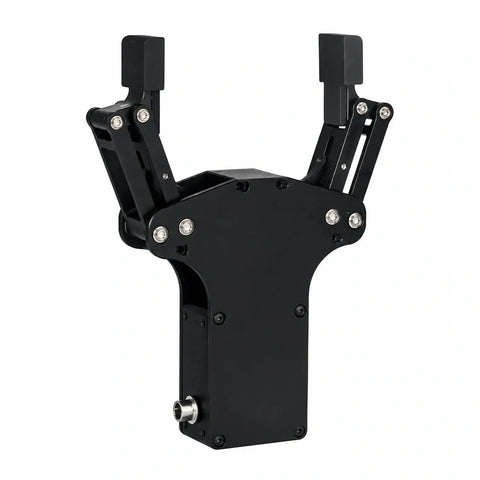
Inspire Robots
Inspire Robots EG2-4B2 Electric Gripper
A compact electric gripper for lighter objects, with adjustable gripping force and RS485 control.Selected configuration: EG2-4B2...
Commercial use onlyRobotic Gripper
$ 1,103.63excl. tax & freight
View
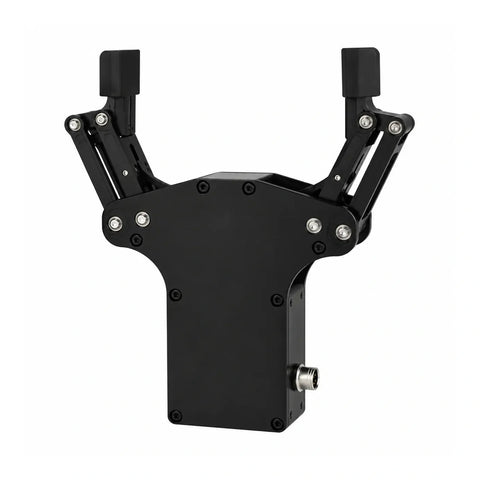
Inspire Robots
Inspire Robots EG2-4C2 Electric Gripper
An electric gripper for stronger gripping force, with adjustable force and RS485 control.Selected configuration: EG2-4C2 /...
Commercial use onlyRobotic Gripper
$ 1,103.63excl. tax & freight
View
 Quote
TESOLLO
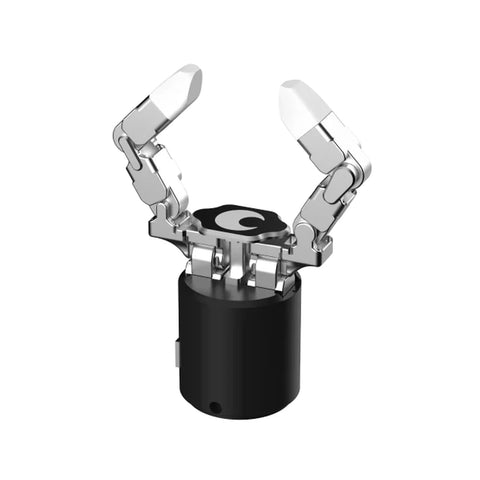
TESOLLO Delto Gripper DG-2F
Articulated two-finger gripper for flexible part handling. Three joints per finger allow the fingertips to adapt their contact position rather than only closing along a fixed parallel-jaw path.
KoreaRobotic Gripper
Quote required
Get quote
 Quote
TESOLLO
TESOLLO Delto Gripper DG-3F-M
Three-finger gripper for stable multi-point grasping. Each of the three fingers has four independently controlled joints for adapting grasp shape and contact position.
KoreaRobotic Gripper
Quote required
Get quote
 Quote
TESOLLO
TESOLLO Delto Gripper DG-4F
Four-finger gripper with configurable base joints for flexible manipulation. Its adjustable base-joint structure supports hand-like and conventional gripper-style configurations.
KoreaRobotic Gripper
Quote required
Get quote
UFACTORY
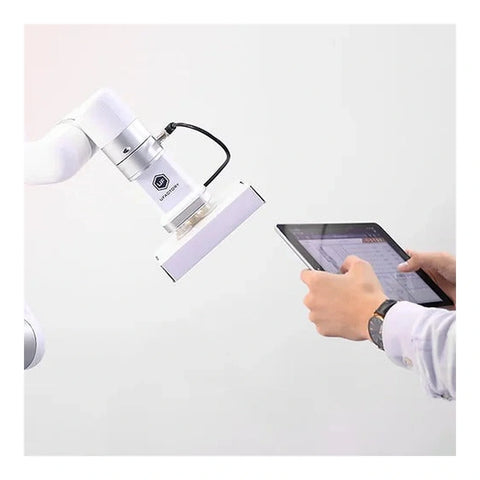
UFACTORY xArm Vacuum Gripper
Electric vacuum gripping for suitable workpieces.Key details Built-in electric vacuum generator Payload up to 5 kg;...
Commercial use onlyRobotic Gripper
$ 720.40excl. tax & freight
View
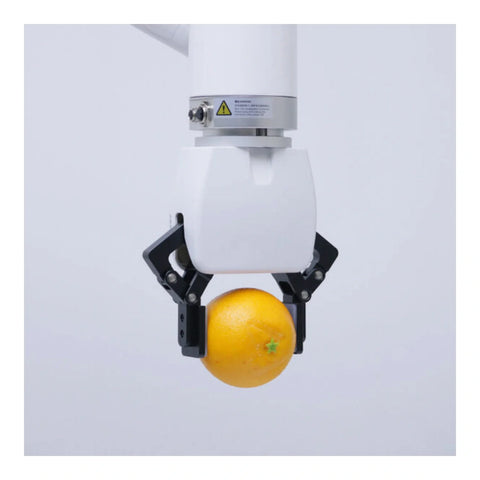
UFACTORY
UFACTORY xArm Gripper G2
Programmable parallel gripping for compatible xArm workflows.Key details 84 ±1 mm stroke, 10-50 N programmable gripping...
Commercial use onlyRobotic Gripper
$ 2,478.20excl. tax & freight
View
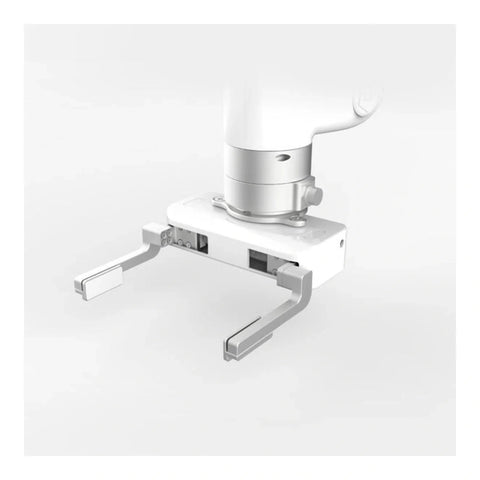
UFACTORY
UFACTORY BIO Gripper G2
A labware-oriented gripper for automated sample handling.Key details 80 mm stroke; 71-150 mm working range with...
Commercial use onlyRobotic Gripper
$ 2,478.20excl. tax & freight
View
 Quote
Robotiq
Robotiq 2F-140 Adaptive Gripper
An adaptive two-finger gripper with 140 mm stroke and up to 2.5 kg payload. Its wider...
CanadaRobotic Gripper
Quote required
Get quote
 Quote
Robotiq
Robotiq Hand-E Adaptive Gripper — 50 mm
Selected configuration: one standard Robotiq Hand-E adaptive gripper with 50 mm parallel stroke.For assembly and machine...
CanadaRobotic Gripper
Quote required
Get quote
 Quote
Robotiq
Robotiq 2F-85 Adaptive Gripper
An adaptive two-finger gripper with 85 mm stroke and up to 5 kg payload. Parallel and...
CanadaRobotic Gripper
Quote required
Get quote
 Quote
AUBO
AUBO Palletizing End-of-Arm Tooling
Suction cups and clamp grippers for AUBO palletizing cells, in rubber, foam, split and clamp configurations.
Robotic Gripper
Quote required
Get quote
Origin
Products marked commercial use only are offered to commercial and education customers and are not available for defense or government programmes. If TAA compliance is a requirement, start with TESOLLO — Korean-manufactured, and the only multi-finger line we carry that covers both hands and grippers.
Tell us your end customer at the consult stage and we will configure around it.
Compare
| Gripper | Origin | DoF | Force & payload | Control interface | Weight | Gov / defense |
|---|---|---|---|---|---|---|
| TESOLLO DG-3F-M | Korea | 12 (4 per finger) | 2 Nm/finger · Pinch 2.5/5 kg · Envelop 10/15 kg | Modbus RTU/TCP, Ethernet TCP/IP · 333 Hz | 1,114 g | Eligible |
| TESOLLO DG-4F | Korea | 18 | Pinch 3/5 kg · Envelop 10/20 kg | Modbus RTU/TCP, Ethernet TCP/IP | 1,494 g | Eligible |
| TESOLLO DG-2F | Korea | 6 (3 per finger) | Pinch 2/4 kg · Envelop 5/10 kg | Modbus RTU/TCP · 500 Hz | 770 g | Eligible |
| Inspire EG2-4B2 | China | Parallel electric | not published | CAN / RS232 / RS485, selectable at order | not published | Commercial only |
| Inspire EG2-4C2 | China | Parallel electric | not published | CAN / RS232 / RS485, selectable at order | not published | Commercial only |
| uFactory xArm Gripper G2 | China | Parallel, 2-finger | 10-50 N · 5 kg payload · 84 mm stroke | RS-485 Modbus RTU | 800 g | Commercial only |
TESOLLO grippers include integrated pressure sensing and power-off self-locking as standard, and are rated beyond three million cycles. Optional fingertip modules — 6-axis force/torque, 3-axis force, tactile and suction — are configured at order. Specifications are as published by each manufacturer. Where a field reads “not published,” the vendor does not state it publicly — we request it in writing for your evaluation rather than estimate. Stock and lead times are confirmed at quote.
Send us the part, not the spec
Photos or a CAD file of what you are picking tells us more than a requirements document. We will come back with the cheapest end effector that holds it reliably.
Add a force channel
Tactile and force sensing
Most grippers report position and current, and nothing about contact. These add shear, normal force and slip detection to a gripper you already own.
 Quote
NVIDIA
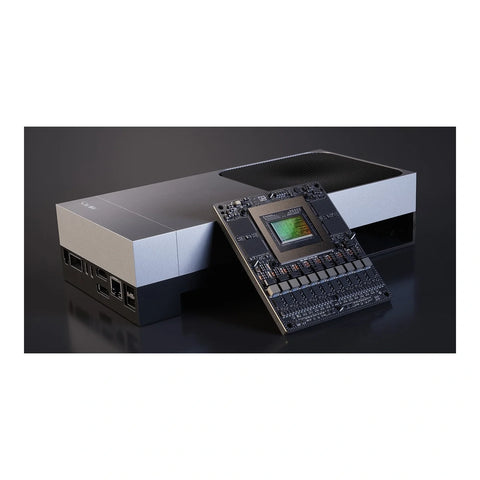
NVIDIA Jetson AGX Thor Developer Kit
The flagship on-robot compute for humanoid and multi-arm platforms. 2,070 FP4 TFLOPS and 128 GB of...
United StatesRobotics Compute
Quote required
Get quote
 Quote
NVIDIA
NVIDIA Jetson AGX Orin Developer Kit (64GB)
On-robot compute for a full-size rig. 275 TOPS and 64 GB of LPDDR5 is enough to...
United StatesRobotics Compute
Quote required
Get quote
 Quote
NVIDIA
NVIDIA DGX Spark (Reference Only)
Reference only. Knoxlabs does not sell or ship the NVIDIA DGX Spark. This page is provided...
United StatesRobotics Compute
Quote required
Get quote
 Quote
NVIDIA
NVIDIA Jetson Orin Nano Super Developer Kit
The entry point into on-robot inference. 67 TOPS in a 100 × 79 mm board at...
United StatesRobotics Compute
Quote required
Get quote
 Quote
Robotiq
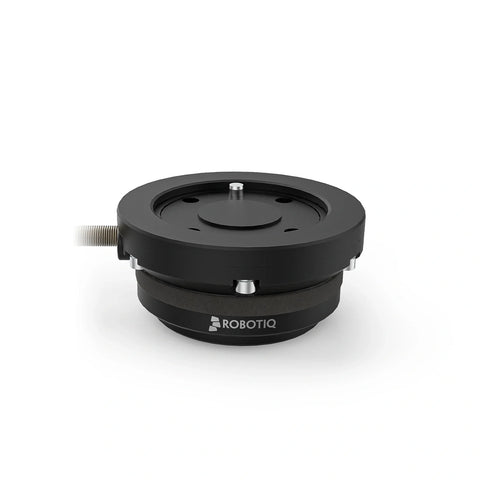
Robotiq FT 300-S Force Torque Sensor
A six-axis wrist-mounted sensor for force-sensitive assembly, insertion, finishing and contact-data collection. The FT 300-S measures...
CanadaForce & Tactile Sensor
Quote required
Get quote
 Quote
Orbbec
Orbbec Multi-Camera Sync Hub Pro
The part of a multi-camera rig nobody budgets for and every dataset needs. Without a common...
Commercial use onlyCapture Infrastructure
Quote required
Get quote
 Quote
Orbbec
Orbbec Multi-Camera Sync Hub Dev — Star
Star-topology trigger hub for a small rig — typically a three or four camera teleoperation cell....
Commercial use onlyCapture Infrastructure
Quote required
Get quote
 Quote
Orbbec
Orbbec Multi-Camera Sync Hub Dev — Daisy Chain
Daisy-chain trigger hub for rigs where cameras run along a rail or frame and star cabling...
Commercial use onlyCapture Infrastructure
Quote required
Get quote
 Quote
Orbbec
Orbbec Sync Adaptor — 8-Pin to RJ45
One adaptor per camera. This is the piece that connects a camera's 8-pin sync port to...
Commercial use onlyCapture Infrastructure
Quote required
Get quote
Luxonis
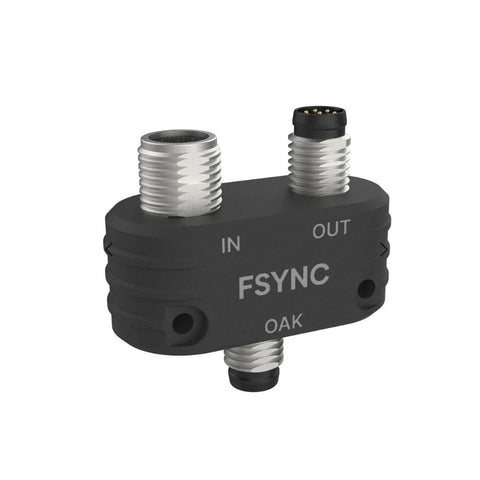
FSync Y-adapter
Synchronize compatible Luxonis OAK cameras at the hardware level for cleaner multi-view capture. The FSync Y-adapter...
United StatesCapture Infrastructure
$ 34.00excl. tax & freight
View
 Quote
XJCSENSOR
XJCSENSOR Robot Force Control Solution, 6-axis F/T sensor + compliance software
XJCSENSOR Robot Force Control Solution, 6-axis F/T sensor + compliance software.Technical specifications are being confirmed with...
Robotics Software
Quote required
Get quote
 Quote
XELA Robotics
XELA Robotics uSkin uSPa 44 Tactile Patch — 500 mm / Corner compensation / Standard calibration
Selected configuration: Cable Length: 500 mm; Magnetic Compensation: Corner; Force Calibration: Standard.Supplier SKU: X0D11000A.XELA Robotics uSPa...
JapanForce & Tactile Sensor
Quote required
Get quote
Talk to us
Tell us what you are building
Send us the task, the robot platform and your timeline. We reply with a configured bill of materials and a quote — usually within one business day.
Form not loading? Request a quote.
Keep exploring
The rest of the robotics stack
Every layer, sourced and deployed by the same team.