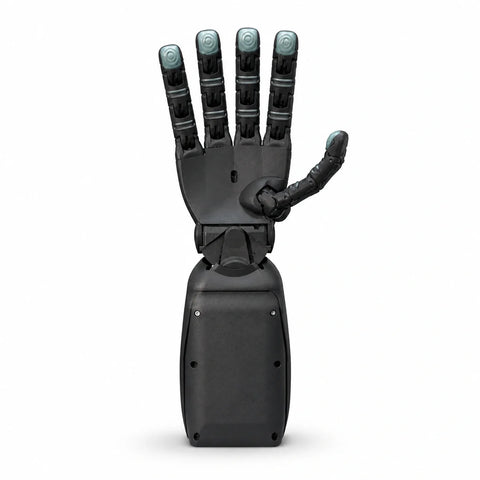
Surge
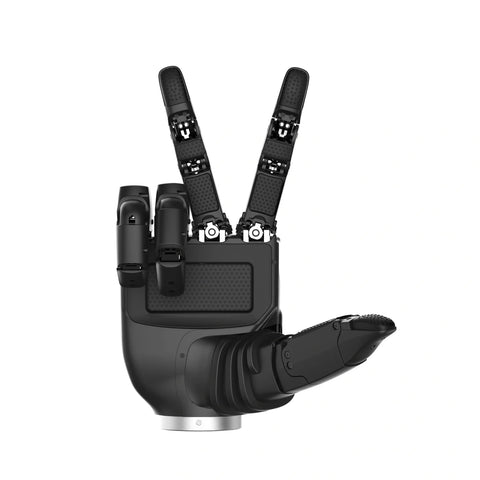
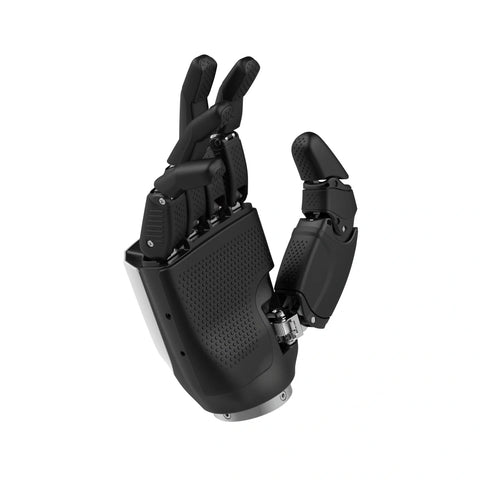
Six powered fingers with field-swappable modules in two to five minutes. Optional 80 addressable taxels per finger.
End effectors
Five-finger hands from four countries, compared on the specifications that decide integrations: actuated degrees of freedom, tactile density, control bus — and country of origin, because for a lot of buyers that is the first filter, not the last.
Decision framework
Q1
If any part of the programme serves a defense or government buyer, origin decides the shortlist before DoF does. Several excellent hands are commercial-only.
Q2
Tactile density ranges from none to 150+ addressable points. If the policy has to detect slip, that spec matters more than finger count.
Q3
CAN FD, EtherCAT, Modbus TCP, RS485 and Ethernet are not interchangeable. Getting this wrong costs weeks, not hours.
Origin, plainly
Products marked commercial use only are offered to commercial and education customers and are not available for defense or government programmes. If TAA compliance is a requirement, start with TESOLLO — Korean-manufactured, and the only multi-finger line we carry that covers both hands and grippers.
Tell us your end customer at the consult stage and we will configure around it.
In the catalog
Every dexterous hand in the Knoxlabs catalog today.
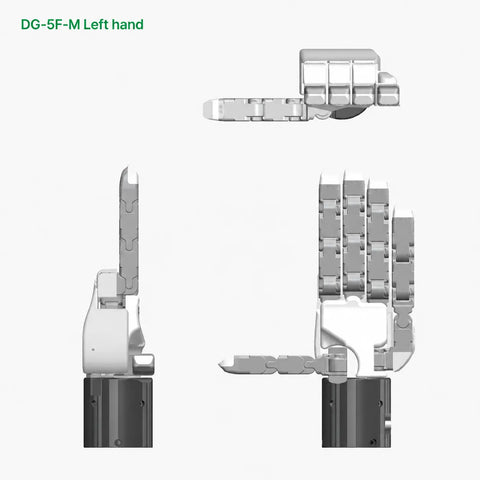
QuoteTESOLLO DG-5F-M robotic hand, left hand, for dexterous manipulation and teleoperation development. Confirm controller, mounting, software mapping and application safety for the complete system.
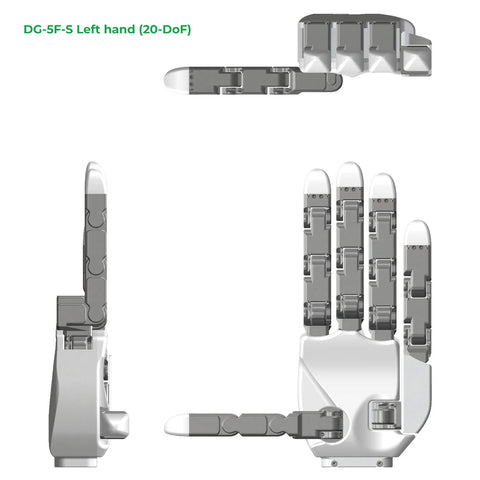
QuoteTESOLLO DG-5F-S 20 DoF robotic hand, left hand, for dexterous manipulation and teleoperation development. Confirm controller, mounting, software mapping and application safety for the complete system.
QuoteA 13-DOF robotic hand for advanced articulation and contact-aware manipulation research. Confirm hand side and hardware...

A tactile robotic hand for contact-aware grasping and humanoid manipulation experiments.Selected configuration: Left / RS485 /...

An all-metal tactile robotic hand for real-time EtherCAT control and repeatable manipulation research.Selected configuration: Left /...

A compact tactile robotic hand for space-constrained integration and contact-aware manipulation experiments.Selected configuration: Left / RS485...

A fast-motion robotic hand for gesture experiments, teleoperation and manipulation research.Selected configuration: Left / With Wrist...

A force-focused robotic hand for stronger grasping, force-feedback experiments and manipulation research.Selected configuration: Left / With...
QuoteThe Seed Robotics RH8D is an adult-size anthropomorphic robot hand with 19 degrees of freedom driven...
QuoteThe RH6D is the child-size member of the Seed Robotics hand family: 15 degrees of freedom...
QuoteThe RH4D is a compact 11-DoF manipulator driven by 4 actuators, with actuated wrist rotation and...
QuoteThe Seed Robotics RH8D is an adult-size anthropomorphic robot hand with 19 degrees of freedom driven...
Available to order
Authorized or in qualification. No stock page yet — quoted per project with confirmed lead times.
Six powered fingers with field-swappable modules in two to five minutes. Optional 80 addressable taxels per finger.
Fully actuated dexterous hand listed by MANUS as a supported platform. Specifications on request from the manufacturer.
12 active DoF across 19, with 150+ tactile points at 0.01 N resolution over CAN FD at 1 kHz.
Full comparison
| Hand | Origin | Actuated / total DoF | Grip & payload | Tactile sensing | Control interface | Weight | Gov / defense |
|---|---|---|---|---|---|---|---|
| TESOLLO DG-5F-M | Korea | 20 / 20 | Pinch 2.5 kg (5 max) · Envelop 10 kg (20 max) | Optional 6-axis F/T, 3-axis, tactile, suction fingertip | Modbus RTU/TCP, Ethernet TCP/IP · 250 Hz · ROS 2 | 1,763 g | Eligible |
| TESOLLO DG-5F-S | Korea | 20 (15 compact option) | Pinch 1/2 kg · Envelop 7/12 kg | Optional fingertip tactile | Ethernet TCP/IP, Modbus TCP · 500 Hz | 880 g | Eligible |
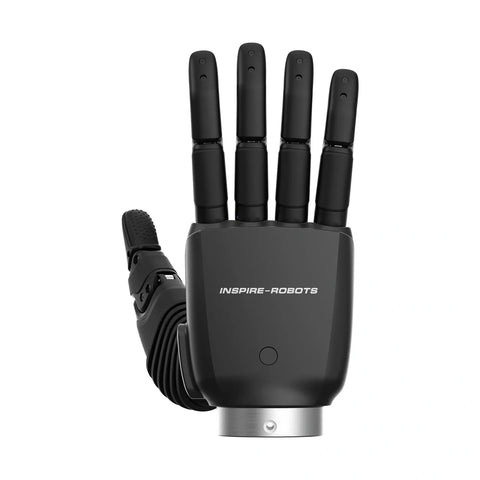
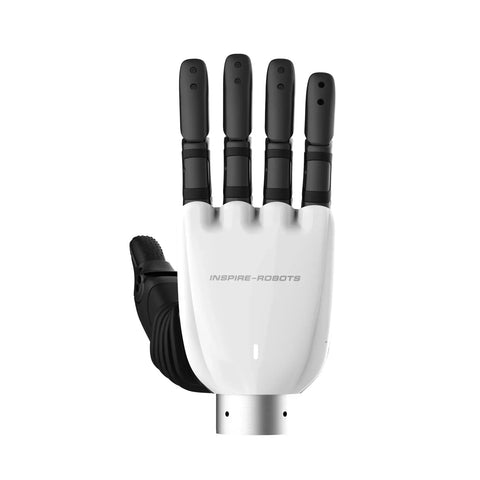
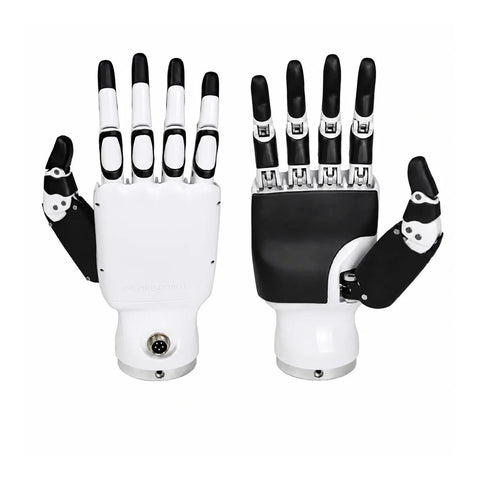
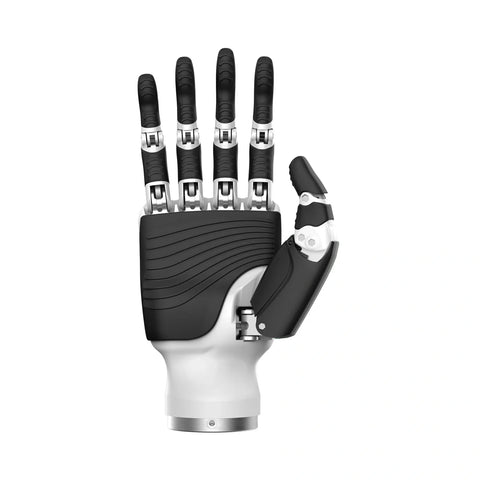
| Inspire RH5DG2 | China | 13 / 18 | not published | 8 high-sensitivity tactile sets | not published | 990 g | Commercial only |
| Inspire RH56E2 | China | 6 / 12 | Fingertip 3 kg · overall load 15 kg | Force sensors, optional palm tactile | ROS | not published | Commercial only |
| Inspire RH56F1 | China | not published | Fingertip 15 N · passive payload 30 kg | Multi-sensor pressure fusion | 1 kHz real-time | not published | Commercial only |
| Inspire RH56H1 | China | not published | not published | 6 pressure sensors, power-off self-locking | 6 linear servo drives, integrated control | 159.7 × 75.2 mm | Commercial only |
| Inspire RH56BFX / RH56DFX | China | 6 / 12 | BFX faster, DFX higher grip force | 6 pressure sensors | ROS | not published | Commercial only |
| Wonik Allegro Hand V4 | Korea | 16 / 16 | Holds up to 5 kg | None built-in | CAN bus, per-joint current control | not published | Eligible |
| PSYONIC Ability Hand | United States | not published | not published | Fingertip pressure with vibration feedback | I2C / UART / RS-485 · ROS 2 · MuJoCo & Isaac Sim wrappers | 490 g · IP64 | Confirm on request |
| Alt-Bionics Surge | United States | 6 / 6 | 4-finger grip 35.5 N · hand lift to 18 kg | Optional 80 addressable taxels per finger | RS485 | 540 g | Confirm on request |
| Seed Robotics RH8D | Portugal | 8 actuators / 19 | 2.5 kg vertical · 1 kg in 3D | Palm ToF, optional 3-axis force to 1 mN | RS485 Dynamixel · open-source ROS package · URDF | 620 g | Eligible |
| AgiBot OmniHand Pro (O12) | China | 12 / 19 | Fingertip 20 N · 35 kg palm-up load | 150+ tactile points, 0.01 N resolution | CAN FD · 1 kHz | ≤750 g | Commercial only |
Specifications are as published by each manufacturer. Where a field reads “not published,” the vendor does not state it publicly — we request it in writing for your evaluation rather than estimate. Stock and lead times are confirmed at quote.
Who buys what
Buy on price, simulation maturity and citability. The Allegro Hand ships as a first-party environment in NVIDIA Isaac Lab, which means your students start from a working example instead of a URDF import. Seed Robotics and PSYONIC ship open ROS support.
Buy on tactile density, bus bandwidth and unit cost at volume. AgiBot and Inspire lead on tactile points per dollar; TESOLLO leads on DoF and is the option that survives an origin review.
Origin is the first filter. TESOLLO (Korea) and Seed Robotics (Portugal) are the straightforward answers. PSYONIC and Alt-Bionics are US-headquartered — we confirm manufacture in writing before quoting against a TAA requirement.
Simulation support
This gets overstated across the industry, so here is the plain version. NVIDIA’s official Isaac Lab environment list contains two dexterous hands: Allegro and Shadow. PSYONIC has announced an Isaac Lab integration and publishes MuJoCo and Isaac Sim wrappers. For every other hand on this page, simulation support means building the asset yourself — which is a normal amount of work, but it is work, and it belongs in your project plan rather than arriving as a surprise in week three.
If you want a hand that runs a published Isaac Lab example on day one, that narrows to Allegro. If you want the best hand for your task and are prepared to author the sim asset, the field is wide open. We will scope either.
Tell us the robot, the bus, the task and the end customer. You will get two or three hands that actually fit, with the trade-off between them written out.
Add a force channel
Fingertip and patch sensors that give a dexterous hand a distributed contact map, not just joint states.
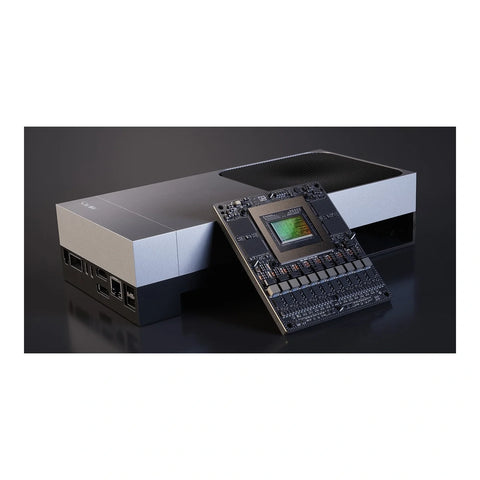
QuoteThe flagship on-robot compute for humanoid and multi-arm platforms. 2,070 FP4 TFLOPS and 128 GB of...
QuoteOn-robot compute for a full-size rig. 275 TOPS and 64 GB of LPDDR5 is enough to...
QuoteReference only. Knoxlabs does not sell or ship the NVIDIA DGX Spark. This page is provided...
QuoteThe entry point into on-robot inference. 67 TOPS in a 100 × 79 mm board at...
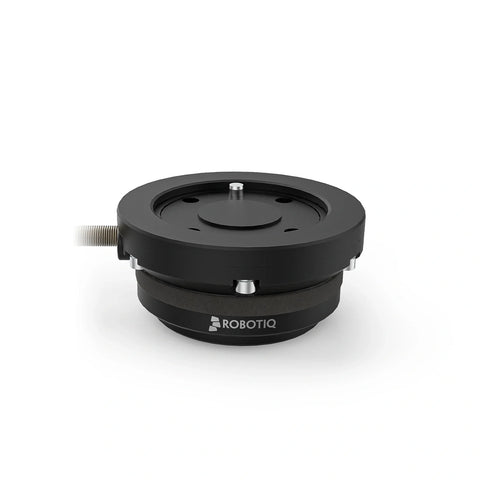
QuoteA six-axis wrist-mounted sensor for force-sensitive assembly, insertion, finishing and contact-data collection. The FT 300-S measures...
QuoteThe part of a multi-camera rig nobody budgets for and every dataset needs. Without a common...
QuoteStar-topology trigger hub for a small rig — typically a three or four camera teleoperation cell....
QuoteDaisy-chain trigger hub for rigs where cameras run along a rail or frame and star cabling...
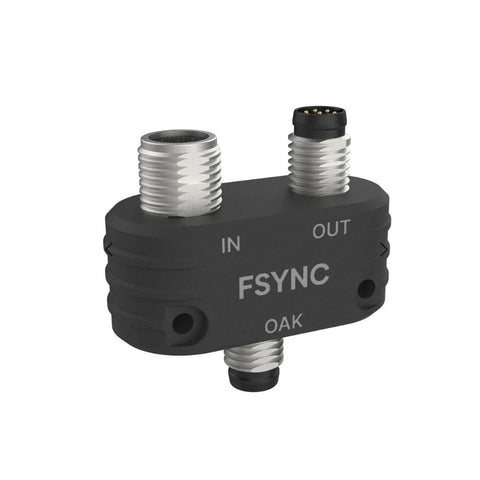
QuoteOne adaptor per camera. This is the piece that connects a camera's 8-pin sync port to...

Synchronize compatible Luxonis OAK cameras at the hardware level for cleaner multi-view capture. The FSync Y-adapter...
QuoteXJCSENSOR Robot Force Control Solution, 6-axis F/T sensor + compliance software.Technical specifications are being confirmed with...
QuoteSelected configuration: Cable Length: 500 mm; Magnetic Compensation: Corner; Force Calibration: Standard.Supplier SKU: X0D11000A.XELA Robotics uSPa...
Talk to us
Send us the task, the robot platform and your timeline. We reply with a configured bill of materials and a quote — usually within one business day.
Form not loading? Request a quote.
Keep exploring
Every layer, sourced and deployed by the same team.