
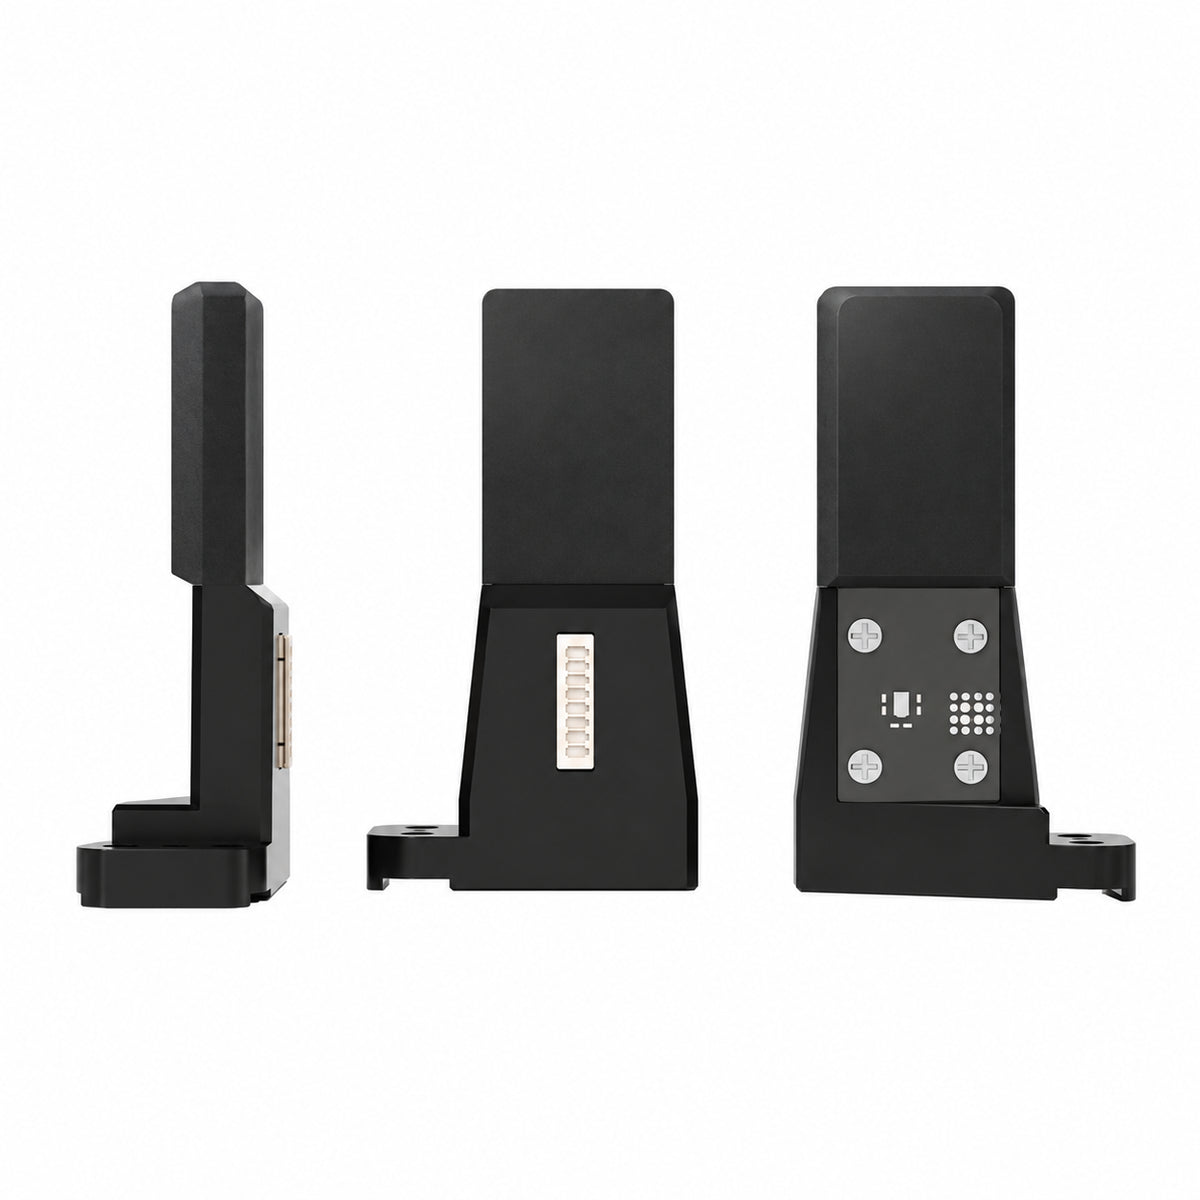
XELA Robotics uSkin uSPr HE35 — Tactile Sensors for Hand-E
Magnetic Compensation: None
Force Calibration: Standard
Your Configuration
All sales are final across all brands. No customer-requested cancellations, returns, exchanges, or refunds, except where required by law or expressly agreed in writing. Manufacturer warranty claims go to the manufacturer; Knoxlabs can help with order details and support contacts.
- Software, hardware, and deployment support can be quoted together.
- Knoxlabs can help with configuration, integration, shipping and support.
Product details
Overview
XELA Robotics uSPr HE35 adds 3-axis tactile sensing to compatible grippers. Each priced piece is one fingertip sensor; a standard two-finger gripper requires two pieces. The gripper is sold separately.
Specifications and compatibility
- For Robotiq Hand-E
- 15 taxels per fingertip
- 3-axis tactile sensing: shear in X/Y and normal force in Z
What is included
Microcontroller and readout/visualization software included. Gripper sold separately. Pricing unit is one fingertip; two pieces required for a standard two-finger gripper.
Select quantity 2 for the two fingertips of a standard two-finger gripper. Images of mounted or paired sensors illustrate the application; the priced item is one fingertip sensor.
Software and calibration
XELA readout and visualization software is included as described below. The catalog describes tactile measurement support for Windows, Linux, ROS and ROS 2. Host support depends on the selected CAN-USB adapter: ESD supports Windows and Linux; VSCOM supports Linux.
Standard calibration uses XELA’s universal parameters. Individual calibration is a paid option for configurations where offered. Magnetic compensation is an optional feature for configurations where offered. Ask Knoxlabs to confirm your complete sensor, controller and adapter setup.
Standard configurations
| Supplier product code | Configuration |
|---|---|
| X1B00000A | Magnetic Compensation: None; Force Calibration: Standard |
| X1B01000A | Magnetic Compensation: None; Force Calibration: Individual |
| X1B10000A | Magnetic Compensation: Corner; Force Calibration: Standard |
| X1B11000A | Magnetic Compensation: Corner; Force Calibration: Individual |
| X1B20000A | Magnetic Compensation: Chess; Force Calibration: Standard |
| X1B21000A | Magnetic Compensation: Chess; Force Calibration: Individual |
Custom configurations — request a quote
These supplier configurations require a project-specific quotation. Share the product code, quantity, target robot and desired delivery date with Knoxlabs.
| Supplier product code | Configuration |
|---|---|
| X1B90000A | uSPr HE35 Custom No |
| X1B91000A | uSPr HE35 Custom Yes |
Application notes
Nearby magnetic fields, magnets and ferromagnetic materials can influence measurements. Confirm suitability in your application; reference sensing and magnetic compensation may be appropriate. Follow XELA’s operating limits and installation guidance. XELA’s sensor remarks state a maximum of 30 N perpendicular force per sensor cell and a shear-pressure limit of 15 kPa.
Pricing, availability and delivery
Request a quote for current pricing, availability, lead time and the complete configuration. Shipping, local taxes, import fees and duties are not included in XELA’s listed product prices and must be confirmed for your order.
Contact Knoxlabs for a configuration quote · Explore XELA Robotics
🛠
Deployment Expertise
Product specialists on staff
⚙
Device Configuration
Provisioned & ready to use
🎧
Enterprise Support
Hardware, software & deployment help
🌐
Global Fulfillment
Shipped worldwide
Need More Than Hardware?
Knoxlabs also handles the deployment.
Device setup
Integration planning
Asset tagging
Shipping coordination
Training and onboarding
Deployment consulting
