

Robotic Gripper
TESOLLO Delto Gripper DG-3F-M
By TESOLLO
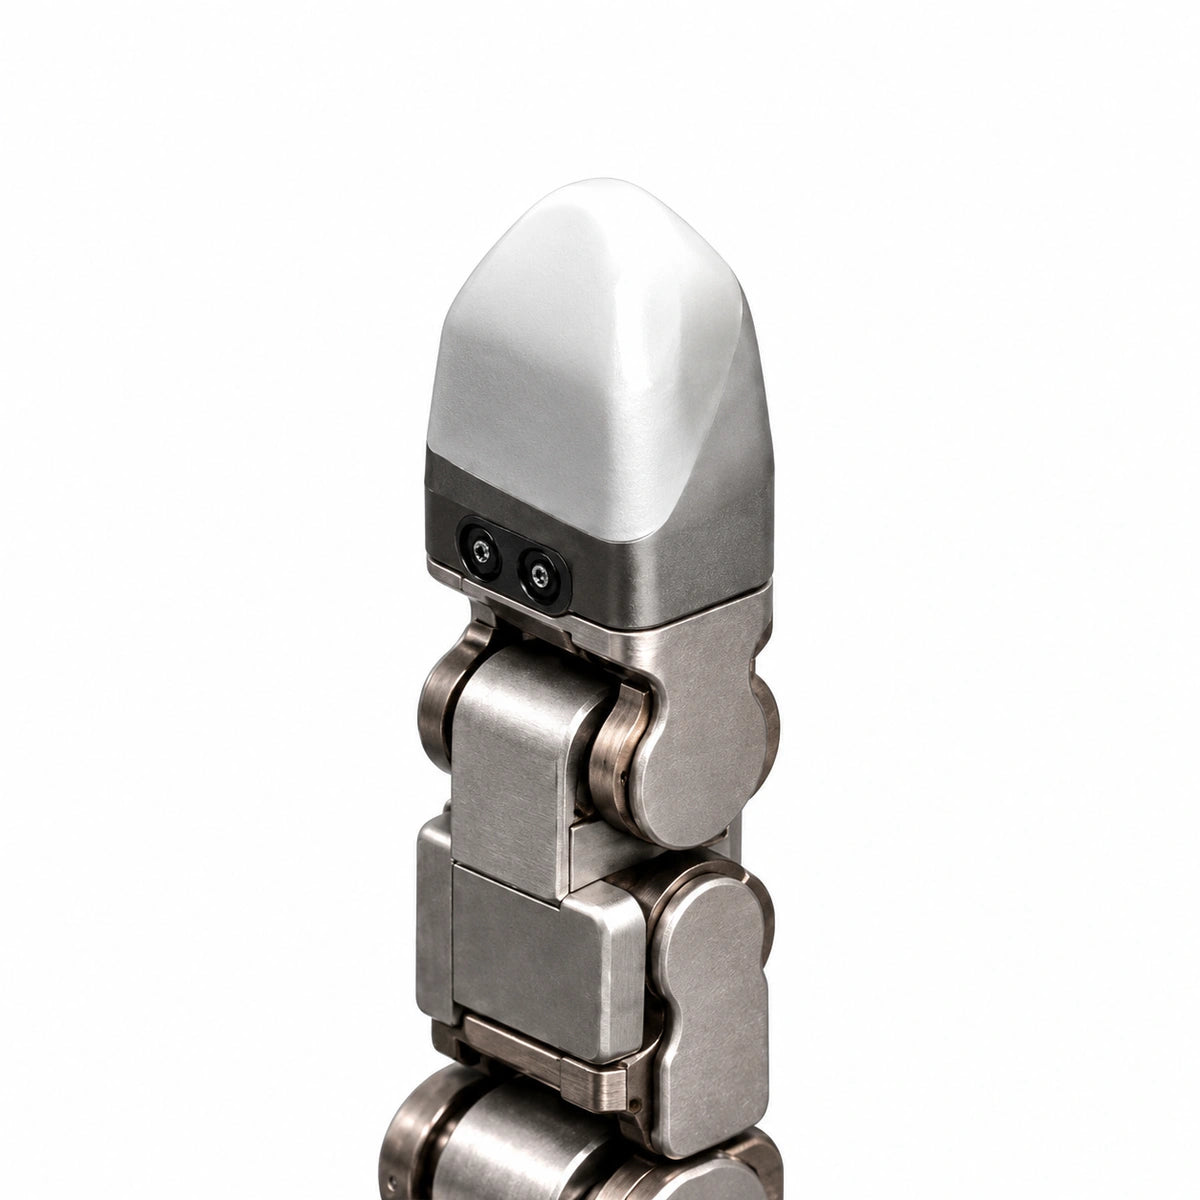
Three-finger gripper for stable multi-point grasping. Each of the three fingers has four independently controlled joints for adapting grasp shape and contact position.
Compatible with Linux · ROS 2
From
Original price
Current price$ 9,000.00
Save $ -9,000.00
Pricing on request
Contact Knoxlabs for a configuration-specific quotation.
Your Configuration
Total
Quote required
One or more selected items need a quote. Your request will include every selected product and quantity.
Quote required for:Pricing on request
All sales are final across all brands. No customer-requested cancellations, returns, exchanges, or refunds, except where required by law or expressly agreed in writing. Manufacturer warranty claims go to the manufacturer; Knoxlabs can help with order details and support contacts.
- Payload depends on object friction, grasp configuration and operating conditions.
- Optional sensors, suction fingertips, mounting hardware and host robot are not included unless itemized in the quotation.
- Lead time, package contents and integration scope are confirmed with the quotation. No fixed production or delivery time is promised.
Product details
Overview
Three-finger gripper for stable multi-point grasping.
Each of the three fingers has four independently controlled joints for adapting grasp shape and contact position.
Applications
Multi-point grasping; manufacturing research; object reorientation; component handling.
Technical specifications
- Degrees of freedom: 12 DoF
- Control frequency: 333 Hz
- Input voltage: 24 V
- Maximum current: 10 A
- Position feedback: Absolute encoder
- Communication: Modbus RTU, Modbus TCP, Ethernet TCP/IP
- Product mass: 1,114 g
- Pinching payload (rated / maximum): 2.5 / 5 kg
- Enveloping payload (rated / maximum): 10 / 15 kg
Payload depends on object friction, grasp configuration and operating conditions.
Integration and ordering
SDK, robot-model and ROS 2 resources are available from TESOLLO. Mounting, electrical integration, controller selection and application safety must be validated for the complete system.
Optional sensors, suction fingertips, mounting hardware and host robot are not included unless itemized in the quotation. Lead time, package contents and integration scope are confirmed with the quotation. No fixed production or delivery time is promised.
Features
- Articulated manipulation—Each of the three fingers has four independently controlled joints for adapting grasp shape and contact position.
- Integration resources—SDK and ROS 2 resources support custom control and robotics development.
- Application planning—Multi-point grasping; manufacturing research; object reorientation; component handling.
Technical Specifications
Product specifications, requirements, and deployment details.
Technical specifications
- Degrees of freedom
- 12 DoF
- Control frequency
- 333 Hz
- Input voltage
- 24 V
- Maximum current
- 10 A
- Position feedback
- Absolute encoder
- Communication
- Modbus RTU, Modbus TCP, Ethernet TCP/IP
- Product mass
- 1,114 g
- Pinching payload (rated / maximum)
- 2.5 / 5 kg
- Enveloping payload (rated / maximum)
- 10 / 15 kg
🛠
Deployment Expertise
Product specialists on staff
⚙
Device Configuration
Provisioned & ready to use
🎧
Enterprise Support
Hardware, software & deployment help
🌐
Global Fulfillment
Shipped worldwide
Need help with deployment?
Knoxlabs also handles the deployment.
Device setup
Integration planning
Asset tagging
Shipping coordination
Training and onboarding
Deployment consulting
FAQ
What is included?
Optional sensors, suction fingertips, mounting hardware and host robot are not included unless itemized in the quotation. Lead time, package contents and integration scope are confirmed with the quotation. No fixed production or delivery time is promised.
What integration resources are available?
TESOLLO provides SDK, robot-model and ROS 2 resources. Select a supported controller and software version, then validate communications, mounting and safety in your own system.
How should I select this model?
Select based on object geometry, required grip mode, payload, robot payload budget and integration requirements. Knoxlabs can help scope the configuration before quoting.
