
Robotic Gripper
TESOLLO Delto Gripper DG-1F
By TESOLLO
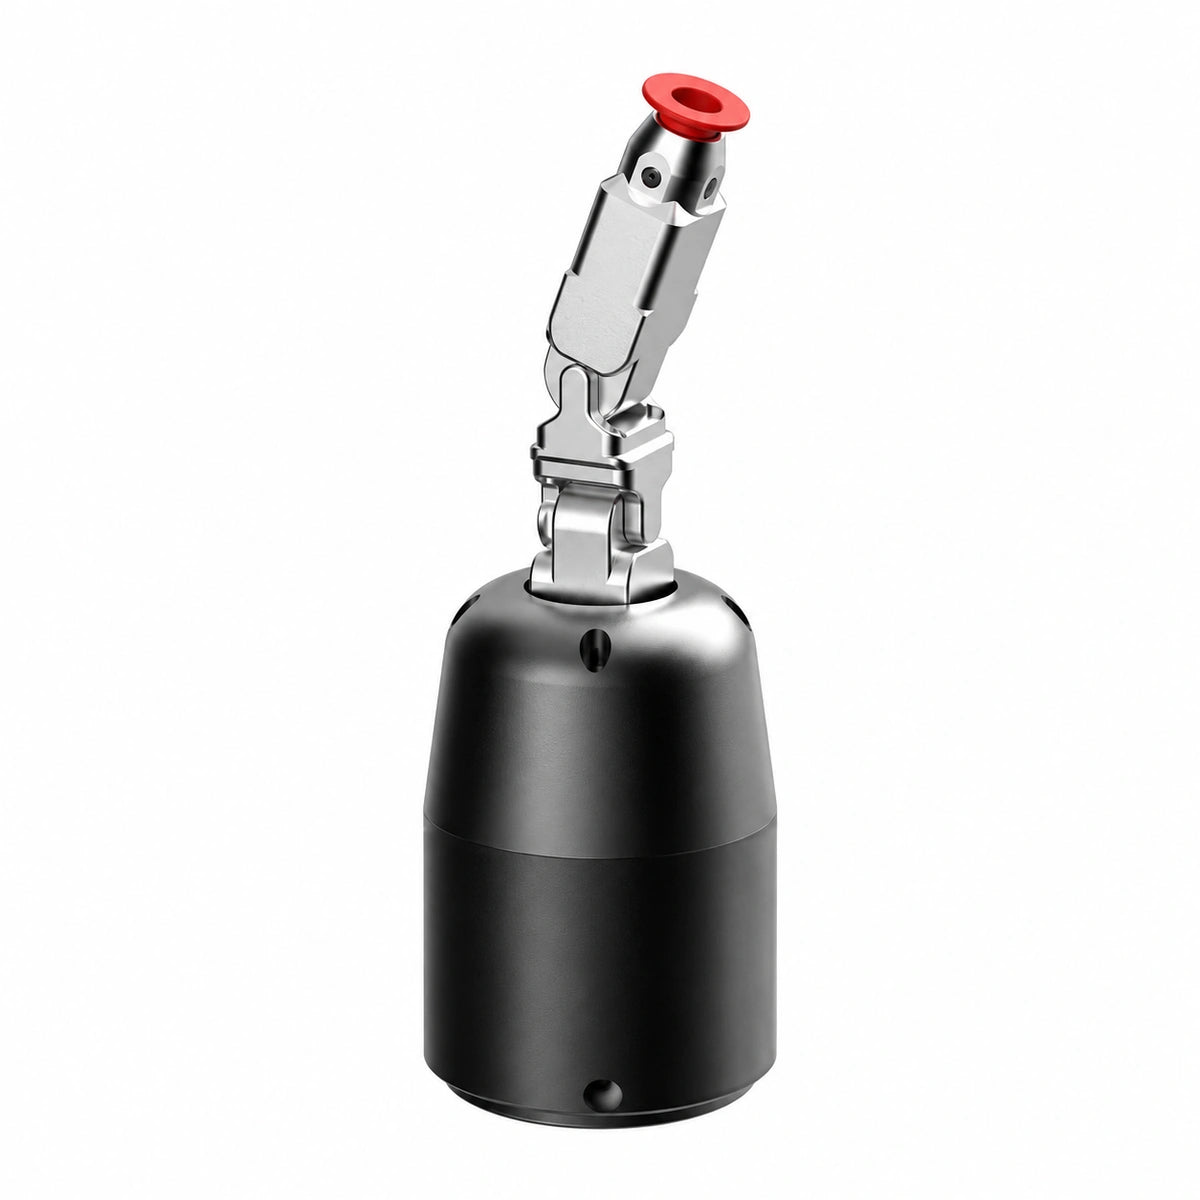
Articulated vacuum gripper for picking objects in confined spaces. The articulated suction fingertip adjusts its approach to the target surface. An external vacuum source is required; validate object surface, seal and application safety before integration.
Compatible with Linux · ROS 2
Contact Knoxlabs for a configuration-specific quotation.
Your Configuration
All sales are final across all brands. No customer-requested cancellations, returns, exchanges, or refunds, except where required by law or expressly agreed in writing. Manufacturer warranty claims go to the manufacturer; Knoxlabs can help with order details and support contacts.
- Payload depends on object friction, grasp configuration and operating conditions.
- External vacuum source required. Confirm pneumatic equipment and supplied components in the quotation.
- Lead time, package contents and integration scope are confirmed with the quotation. No fixed production or delivery time is promised.
Product details
Overview
Articulated vacuum gripper for picking objects in confined spaces.
The articulated suction fingertip adjusts its approach to the target surface. An external vacuum source is required; validate object surface, seal and application safety before integration.
Applications
Logistics piece picking; confined-space handling; transfer of vacuum-compatible small components.
Technical specifications
- Degrees of freedom: 3 DoF
- Control frequency: 1,000 Hz
- Input voltage: 24 V
- Maximum current: 10 A
- Position feedback: Absolute encoder
- Communication: Modbus RTU, Modbus TCP, Ethernet TCP/IP
- Product mass: 710 g
Payload depends on object friction, grasp configuration and operating conditions.
Integration and ordering
SDK, robot-model and ROS 2 resources are available from TESOLLO. Mounting, electrical integration, controller selection and application safety must be validated for the complete system.
External vacuum source required. Confirm pneumatic equipment and supplied components in the quotation. Lead time, package contents and integration scope are confirmed with the quotation. No fixed production or delivery time is promised.
Features
- Articulated manipulation—The articulated suction fingertip adjusts its approach to the target surface. An external vacuum source is required; validate object surface, seal and application safety before integration.
- Integration resources—SDK and ROS 2 resources support custom control and robotics development.
- Application planning—Logistics piece picking; confined-space handling; transfer of vacuum-compatible small components.
Technical Specifications
Everything you need to know about tracking, performance, connectivity, and deployment hardware.
Technical specifications
- Degrees of freedom
- 3 DoF
- Control frequency
- 1,000 Hz
- Input voltage
- 24 V
- Maximum current
- 10 A
- Position feedback
- Absolute encoder
- Communication
- Modbus RTU, Modbus TCP, Ethernet TCP/IP
- Product mass
- 710 g
🛠
Deployment Expertise
Product specialists on staff
⚙
Device Configuration
Provisioned & ready to use
🎧
Enterprise Support
Hardware, software & deployment help
🌐
Global Fulfillment
Shipped worldwide
Need More Than Hardware?
Knoxlabs also handles the deployment.
Device setup
Integration planning
Asset tagging
Shipping coordination
Training and onboarding
Deployment consulting
FAQ
What is included?
External vacuum source required. Confirm pneumatic equipment and supplied components in the quotation. Lead time, package contents and integration scope are confirmed with the quotation. No fixed production or delivery time is promised.
What integration resources are available?
TESOLLO provides SDK, robot-model and ROS 2 resources. Select a supported controller and software version, then validate communications, mounting and safety in your own system.
How should I select this model?
Select based on object geometry, required grip mode, payload, robot payload budget and integration requirements. Knoxlabs can help scope the configuration before quoting.
